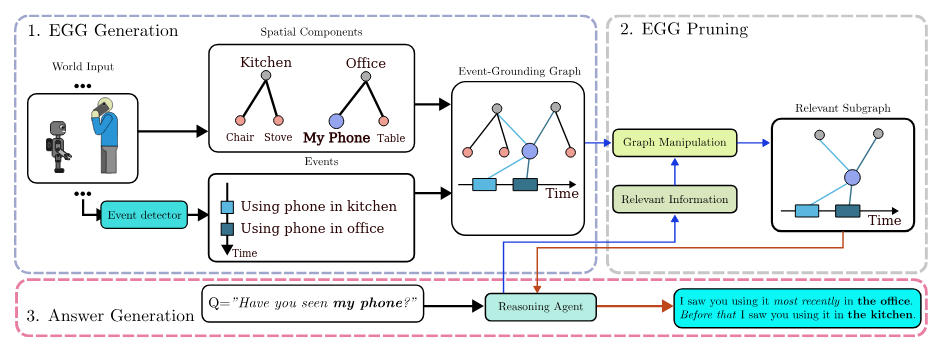
I presented our work: "Event-Grounding Graph: Unified Spatio-Temporal Scene Graph from Robotic Observations" at IROS 2026 in Pittsburgh, PA, United States
I presented our work: “Event-Grounding Graph: Unified Spatio-Temporal Scene Graph from Robotic Observations” [1] at IROS 2026 in Pittsburgh, PA, United States